Looking for dependable YEJ series electromagnetic brake motors? This guide covers trusted suppliers, key quality indicators, and practical buying tips to help you source reliable units with confidence.
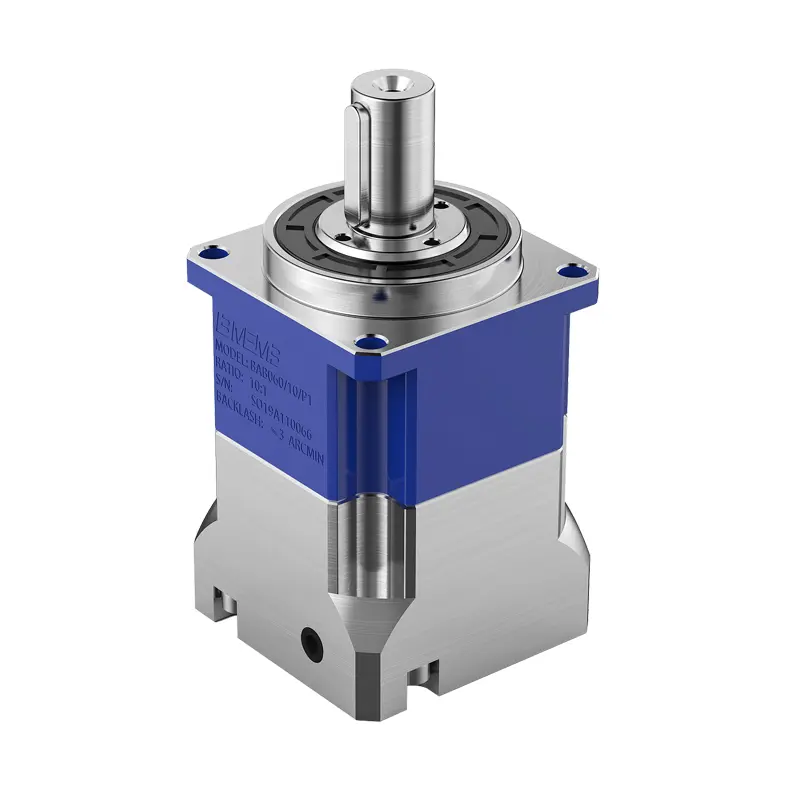
This article explores whether a planetary gearbox can be backdriven, explaining how factors such as gear ratio, efficiency, friction, and self-locking behavior determine if torque can be transmitted in reverse from the output shaft to the input shaft.
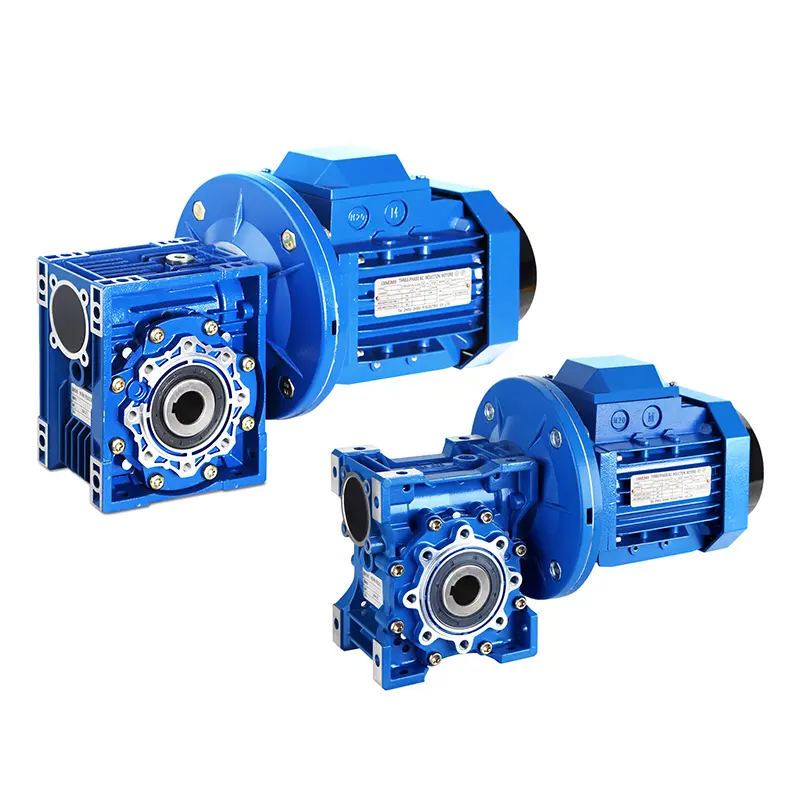
BMRV worm gearboxes offer a range of reduction ratios to suit different speed and torque requirements. Common ratios include 7.5:1, 10:1, 15:1, 20:1, 25:1, 30:1, 40:1, 50:1, 60:1, 80:1, and 100:1, depending on the specific model and size.
Learn how to calculate the output torque of a PC helical gearbox using input power, speed, gear ratio, and efficiency, with a straightforward formula and key practical considerations for accurate sizing and selection.
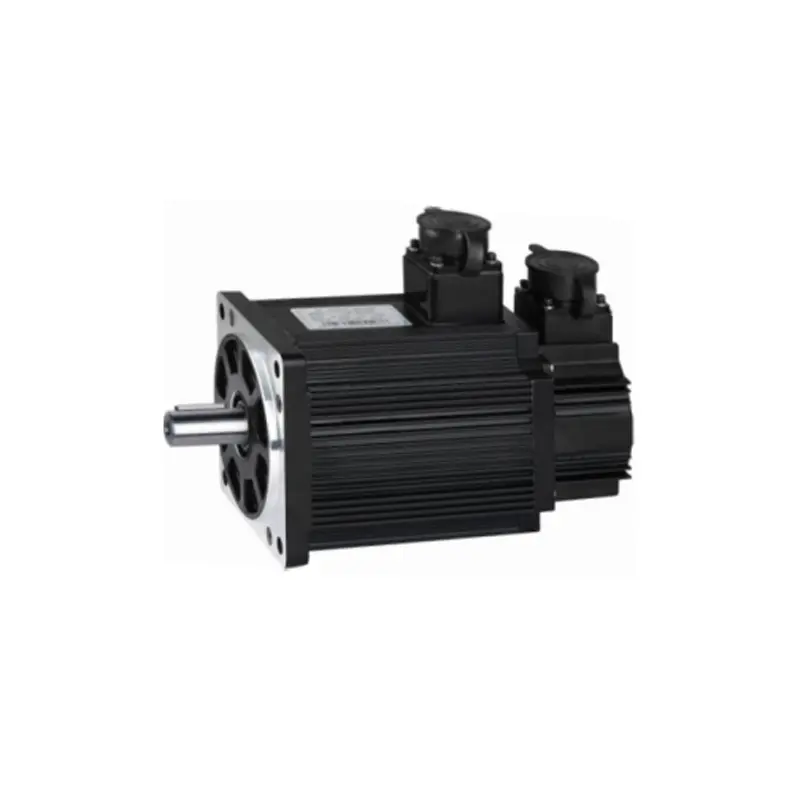
This article explores the most common failure modes of AC permanent magnet servo motors, including bearing wear, rotor demagnetization, insulation breakdown, encoder faults, and overheating, along with their typical causes and preventive measures.
Explore the suitability of 90 series AC servo motors for robotic applications, considering factors like torque, precision, size, and control requirements.
We use cookies to offer you a better browsing experience, analyze site traffic and personalize content. By using this site, you agree to our use of cookies. Privacy Policy